Sub-Compact UHV-Compatible 6-DOF Precision Positioner
Combining Parallel Kinematics and Bi-Phase Rotary Piezo Inertia Drives for Compact Six-Axis Precision Positioning in Ultra High Vacuum
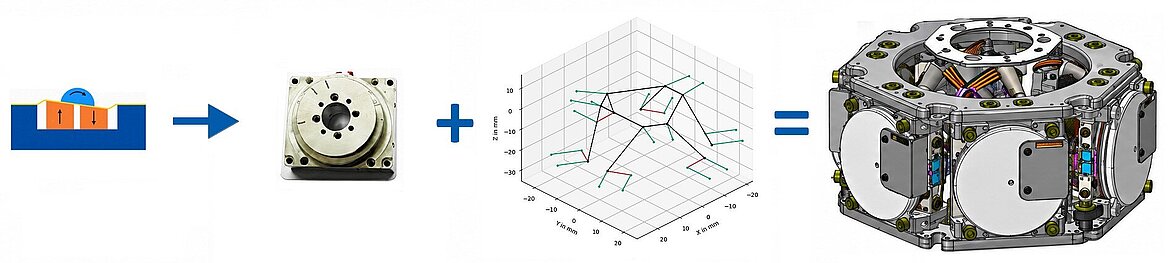
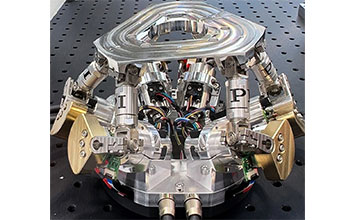
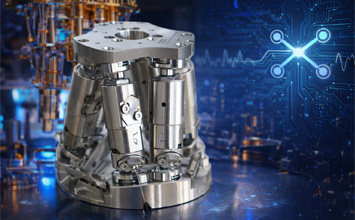
Precision positioning in ultrahigh vacuumenvironments often comes with competing requirements: long travel, high payload capacity, high resolution, long service life and minimal installation space. Meeting all five demands in a compact six-axis system requires a different approach to both the mechanics and the drives. PI's BIX-Hexapod research prototype combines rotary piezoelectric bi-phase inertia drives with a lever-based parallel kinematic mechanism. Measuring just 81mm in diameter and 42mm in height, the prototype demonstrates millimeter-scale travel, fine incremental motion, and position holding functionality without continuous power. BIX is an advanced piezo inertia technology invented by PI.
A Different Approach to Hexapod Motion
A conventional Stewart-Gough hexapod moves its platform by changing the lengths of six independently actuated struts. The BIX-Hexapoduses a different approach. Its six passive struts remain at a constant length, while rotary piezo inertia drives move their lower joints along circular paths.
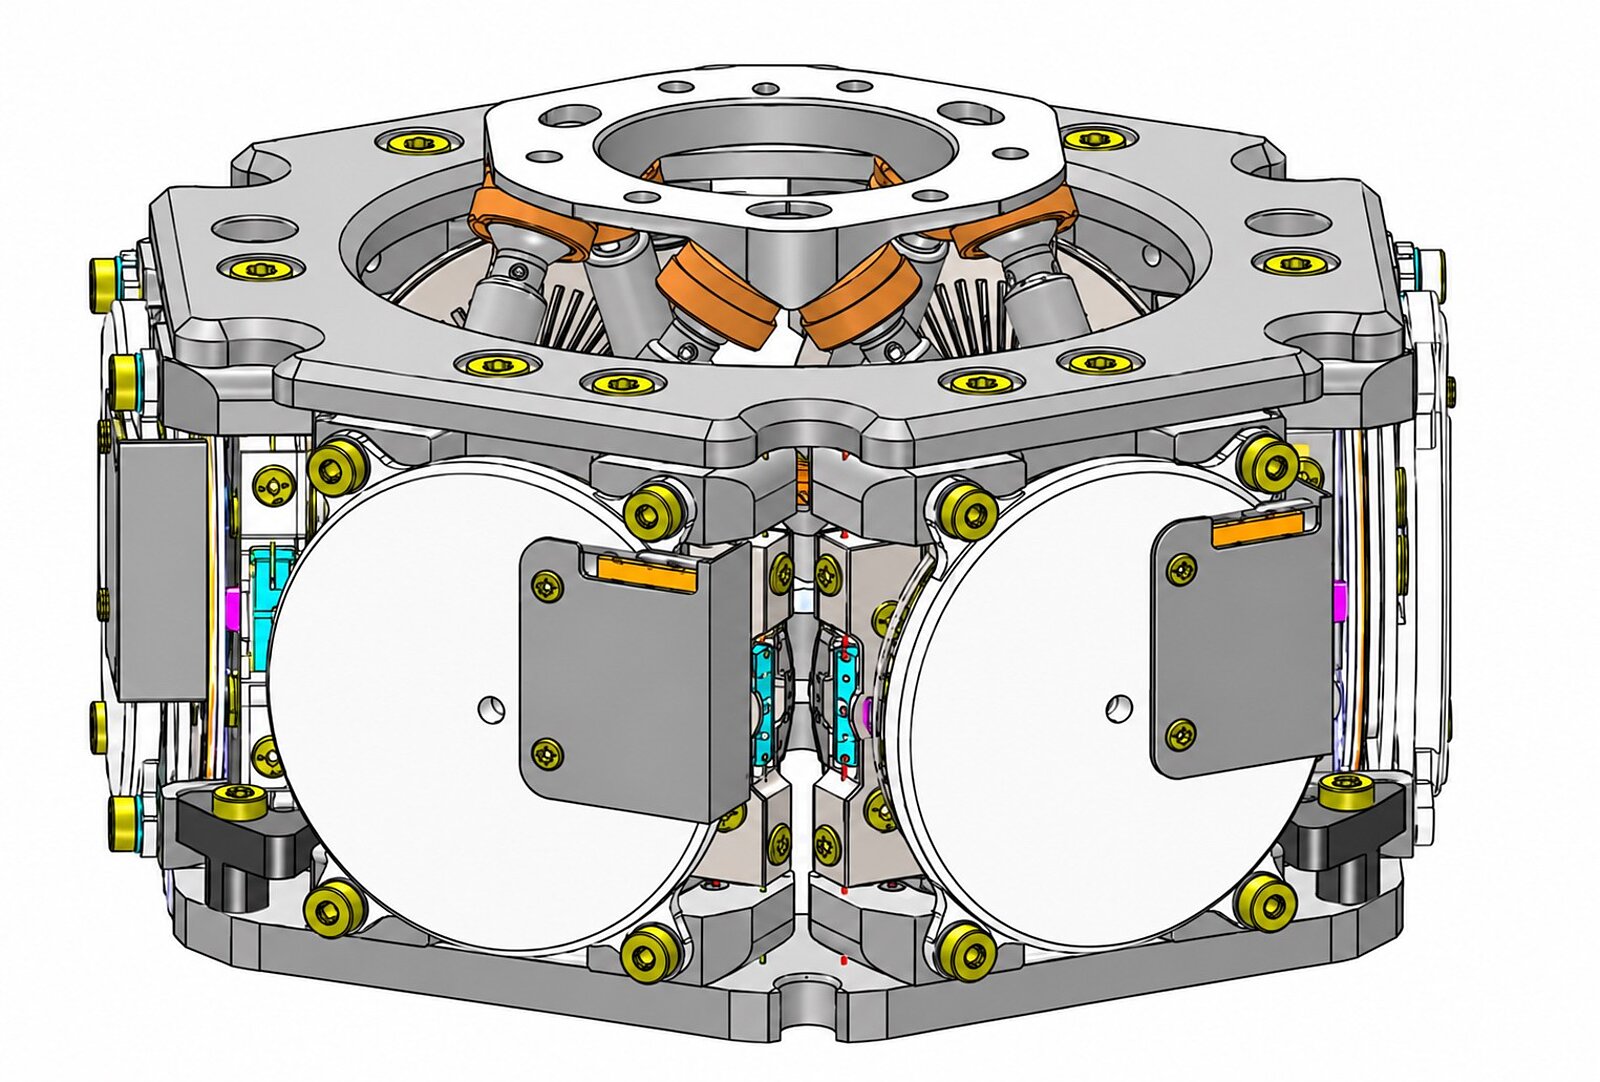
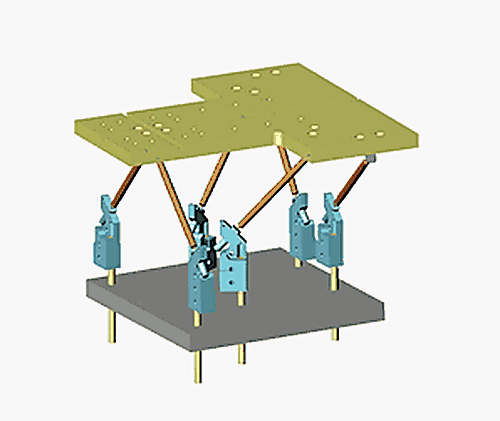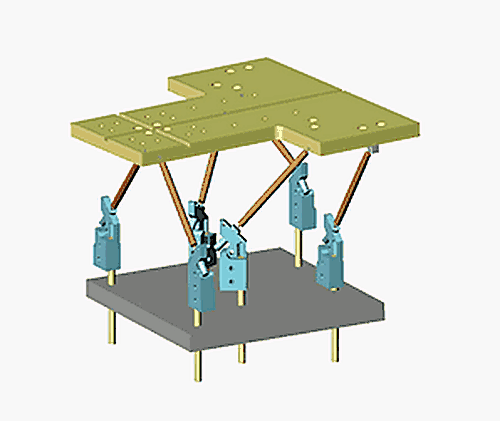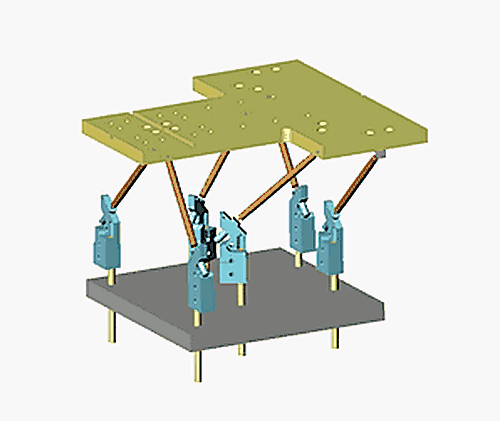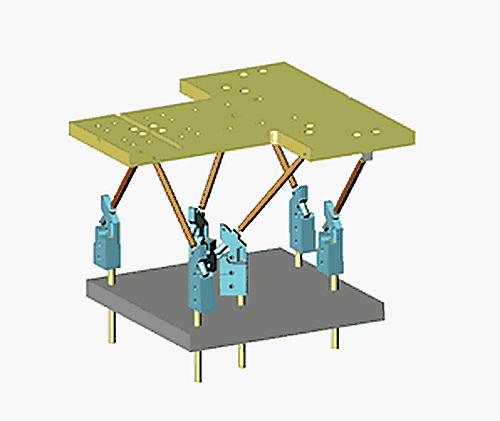
Each rotary drive actuates a lever that transmits motion through a passive strut to the moving platform. Coordinating the six drives produces translation along X, Y, and Z and rotation about all three axes.
The lever mechanism makes it possible to convert only a few degrees of rotary drive motion into millimeter-scale Cartesian displacement. This allows the compact rotary drives to generate a comparatively large system workspace. On top of the incremental motion based on repetitive steps, this type of piezo mechanism also enables continuous, analog mode over a small
How BIX Bi-Phase Inertia Drives Work
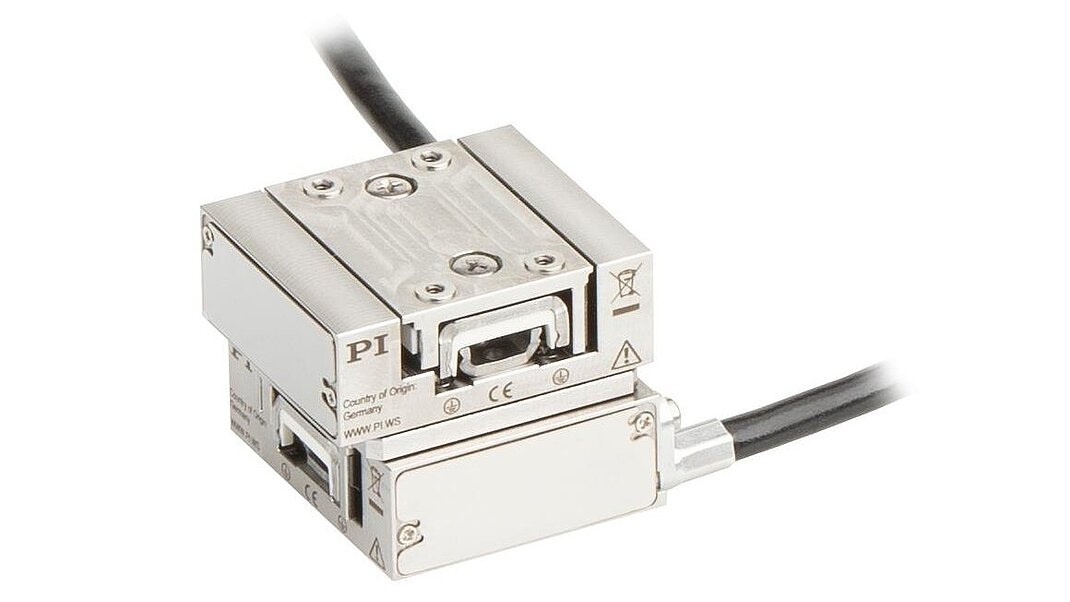
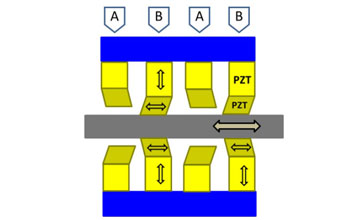
BIX stick-slip motors use two multilayer piezoelectric actuators driven by a modified sawtooth voltage signal. During slow expansion, friction transfers the actuator motion to the rotor (in a rotary drive) or runner (in a linear drive). When the actuator contracts rapidly, within microseconds, the payload’s inertia prevents it from following the return motion. Repeating this stick-slip cycle produces net macroscopic rotary motion in our case, while a symmetrical motor configuration provides consistent operation in both directions.
The self-locking behavior of BIX actuators also allows the hexapod platform to maintain its position even when power is turned off, without the need for an additional locking mechanism.

Small Joints Help Reduce the Footprint
Miniaturizing the drives alone is not enough. The joints connecting the passive struts can also limit how small a parallel kinematic mechanism can become.
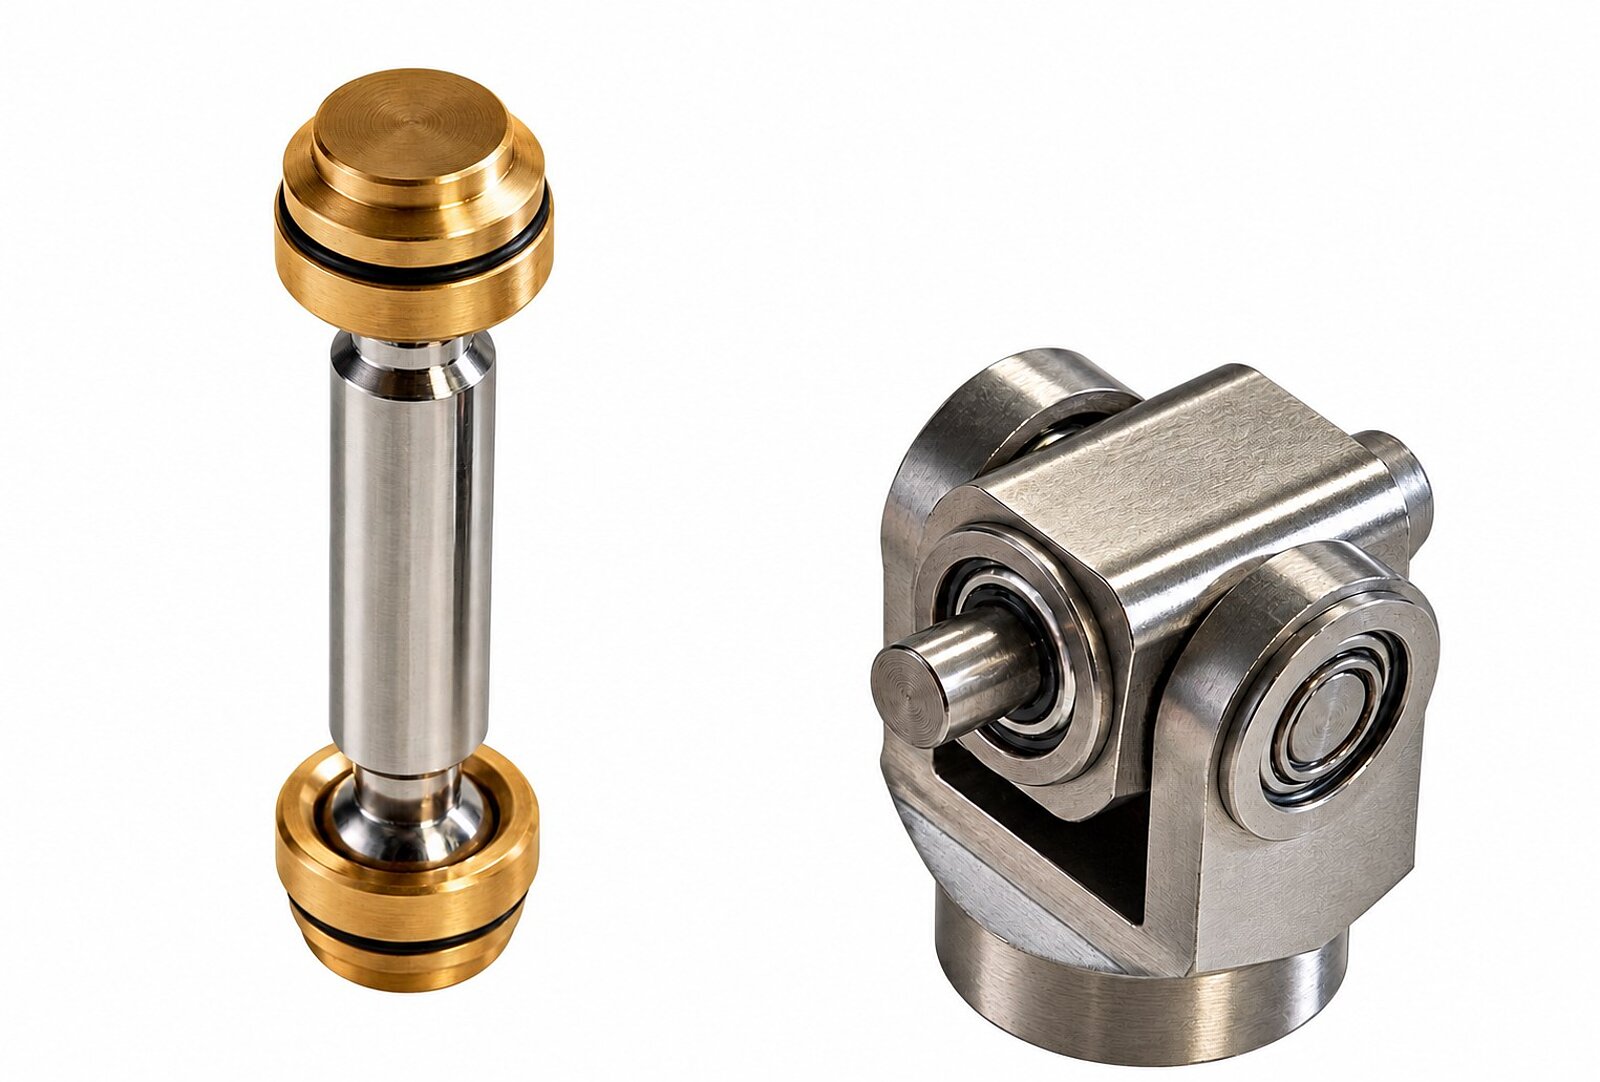
Conventional joint designs based on ball bearings could not be made sufficiently small for this architecture. Instead, BIXLePH uses miniature spherical joints connecting the passive struts. Because the struts and joints fit inside the mechanism, they do not require additional external installation space. The architecture also avoids moving cables during platform motion, while heat generation is confined to the individual drive units. These characteristics support the development of compact positioning systems for thermally sensitive vacuum applications.
What the Prototype Demonstrated
Despite its Ø81 mm × 42 mm dimensions, the first functional prototype provides substantial translational and rotational travel.
| Specification | Value |
| Diameter / height | Ø81mm / 42mm |
| Translation X, Y / Z | 12mm / 6mm |
| Rotation U, V / W | 24° / 40° |
| Payload* | 1,000 g |
| Maximum speed** | 5mm/s short term; 0.5mm/s long term |
| First natural frequency | ≥150Hz @126g payload |
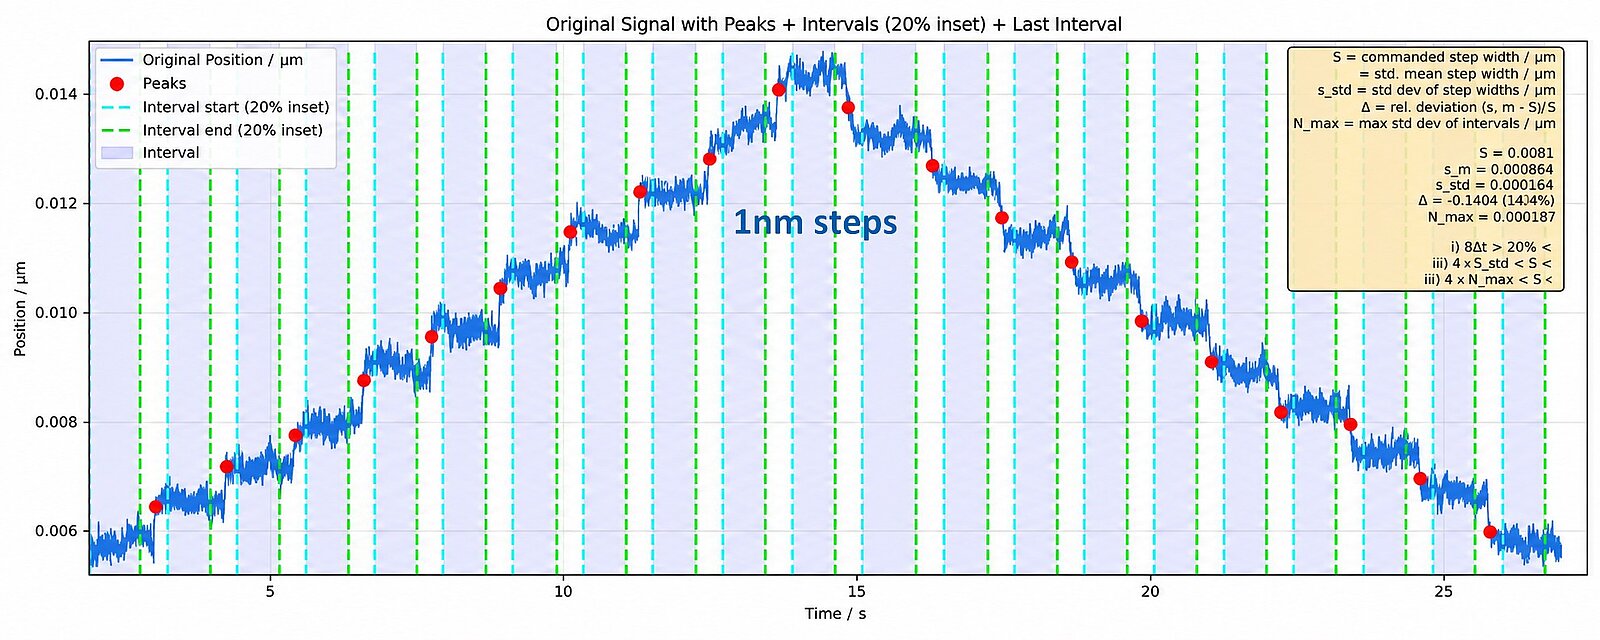
| MIM X / Y / Z | 100nm / 50nm / 2nm |
| Mean unidirectional system repeatability X, Y | <200nm |
| Mean unidirectional system repeatability Z | <50nm |
| In-position stability*** | <1nm |
| Environment | UHV, 1 × 10⁻⁷ mbar at ambient temperature |
* Upright orientation
** Maximum velocity around center; temperature limited
*** RMS value measured over a period of 60 seconds using an external interferometer measurement
Other Z-axis measurements also demonstrated reproducible 780 picometer steps. This is an experimental result and should be distinguished from the targeted performance. Components and materials were selected with ultrahigh-vacuum compatibility in mind, and the prototype was operated both in the laboratory and at pressures below 1 × 10⁻⁷ mbar.
These results of the prototype are very encouraging. BIXLePH is a research platform, and as usual, the first step before commercialization. Further tests and development, therefore, will allow the team to make additional improvements.
A Different Path to Compact 6-DOF Positioning
BIXLePH demonstrates an alternative to simply scaling down a conventional hexapod. The design changes how actuator motion is generated and transferred to the platform.
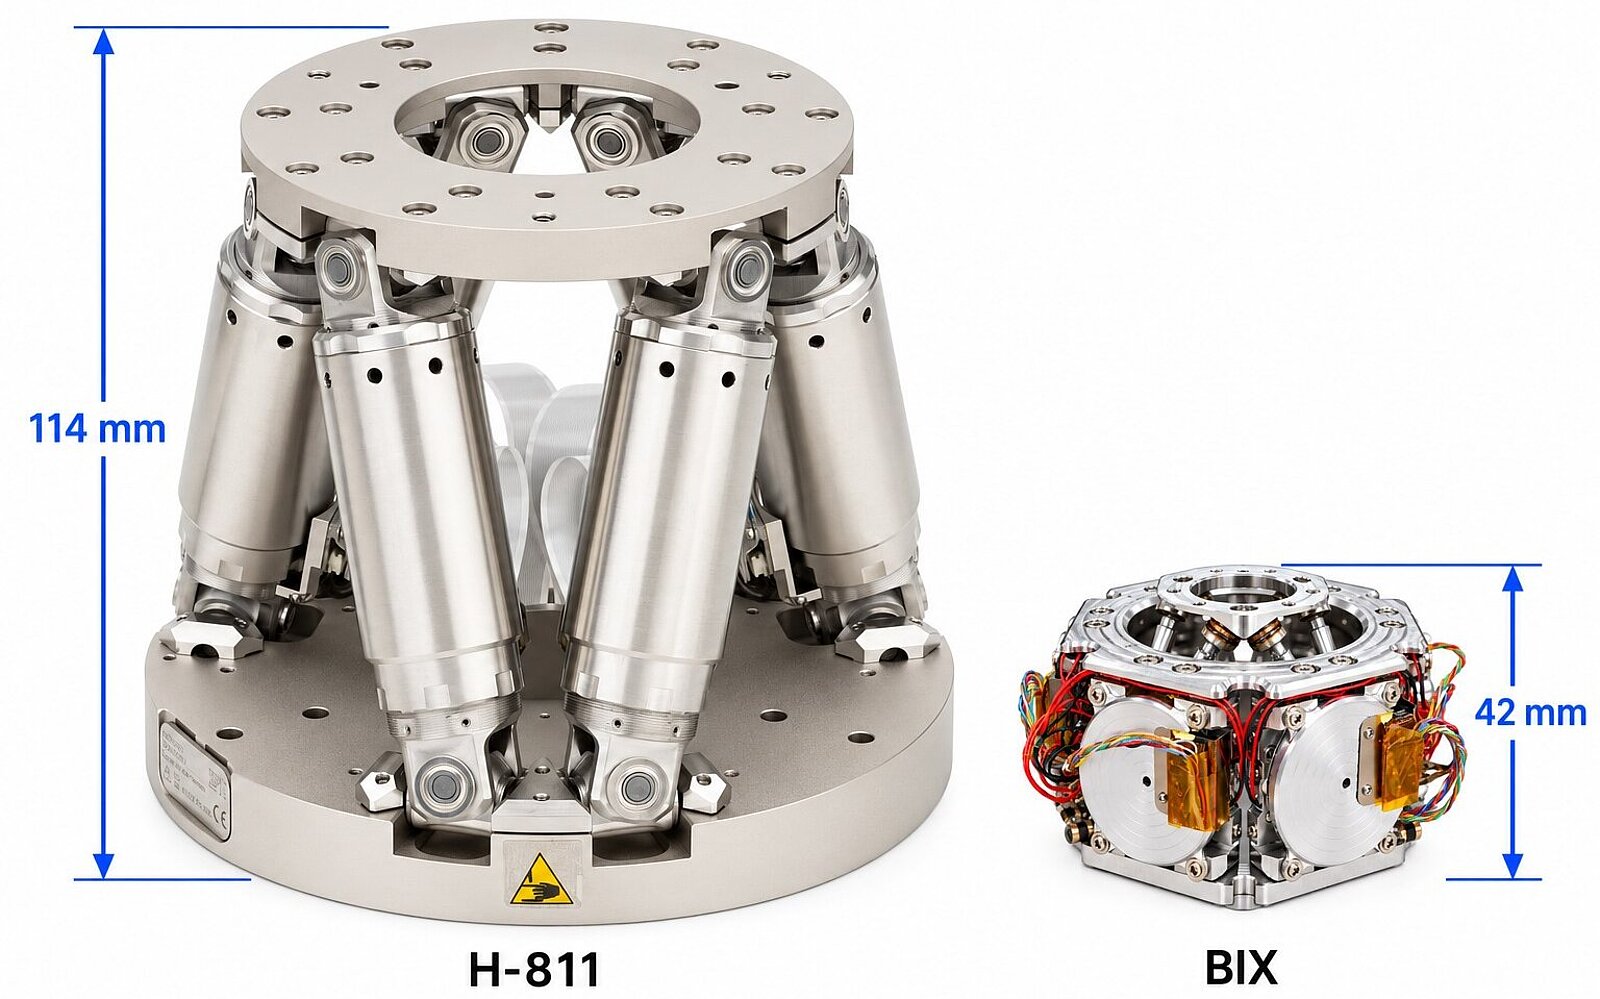
Combining rotary piezo inertia drives, lever transmission, miniature spherical joints, and parallel kinematics results in a mechanism only 42mm high, while providing millimeter-scale XYZ travel, angular motion up to 40°, payload capability up to 1kg, nanometer-scale incremental motion, and UHV compatibility.
There is still development work to be done, but the prototype demonstrates how a different mechanical and drive architecture can address the difficult problem of fitting six-axis precision motion into a very small UHV-compatible package.
Discuss Your Application with PI Engineers
Selecting a six-axis positioning system starts with the application’s requirements. UHV applications require careful consideration of outgassing and material compatibility, while cryogenic operation introduces challenges in thermal behavior, sensing, and power dissipation. On the other hand, cleanroom systems demand contamination control and stability.
PI’s broad range of motion technologies allows our engineers to evaluate these requirements without being tied to a particular drive system. Piezo stack actuators, walking-type piezo motors, inertia drives, DC-motors, voice-coils and 3-phase motors, each offer different advantages. The goal is to select the technology and mechanical configuration that best meet your application’s needs.
Contact a PI expert to discuss your motion range, payload, precision, dynamics, and operating environment. Our team can help you evaluate the trade-offs and select a positioning approach suited to your system.



Blog Categories
- Aero-Space
- Air Bearing Stages, Components, Systems
- Astronomy
- Automation, Nano-Automation
- Beamline Instrumentation
- Bio-Medical
- Hexapods
- Imaging & Microscopy
- Laser Machining, Processing
- Linear Actuators
- Linear Motor, Positioning System
- Metrology
- Microscopy
- Motorized Precision Positioners
- Multi-Axis Motion
- NanoAutomation
- Nanopositioning
- Photonics
- Piezo Actuators, Motors
- Piezo Mechanics
- Piezo Transducers / Sensors
- Precision Machining
- Semicon
- Software Tools
- UHV Positioning Stage
- Voice Coil Linear Actuator
- X-Ray Spectroscopy